Driving
Automated parking, yaw stability, cooperative localization, and vehicle platoon control.
College of Control Science and Engineering, Zhejiang University
Automated parking, yaw stability, cooperative localization, and vehicle platoon control.
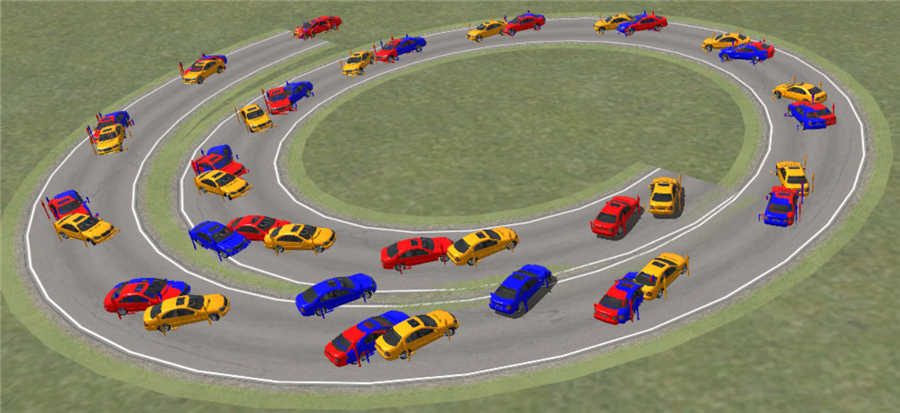
Learning-based MPC, Gaussian processes, iLQR, and safe control near tire-force limits.
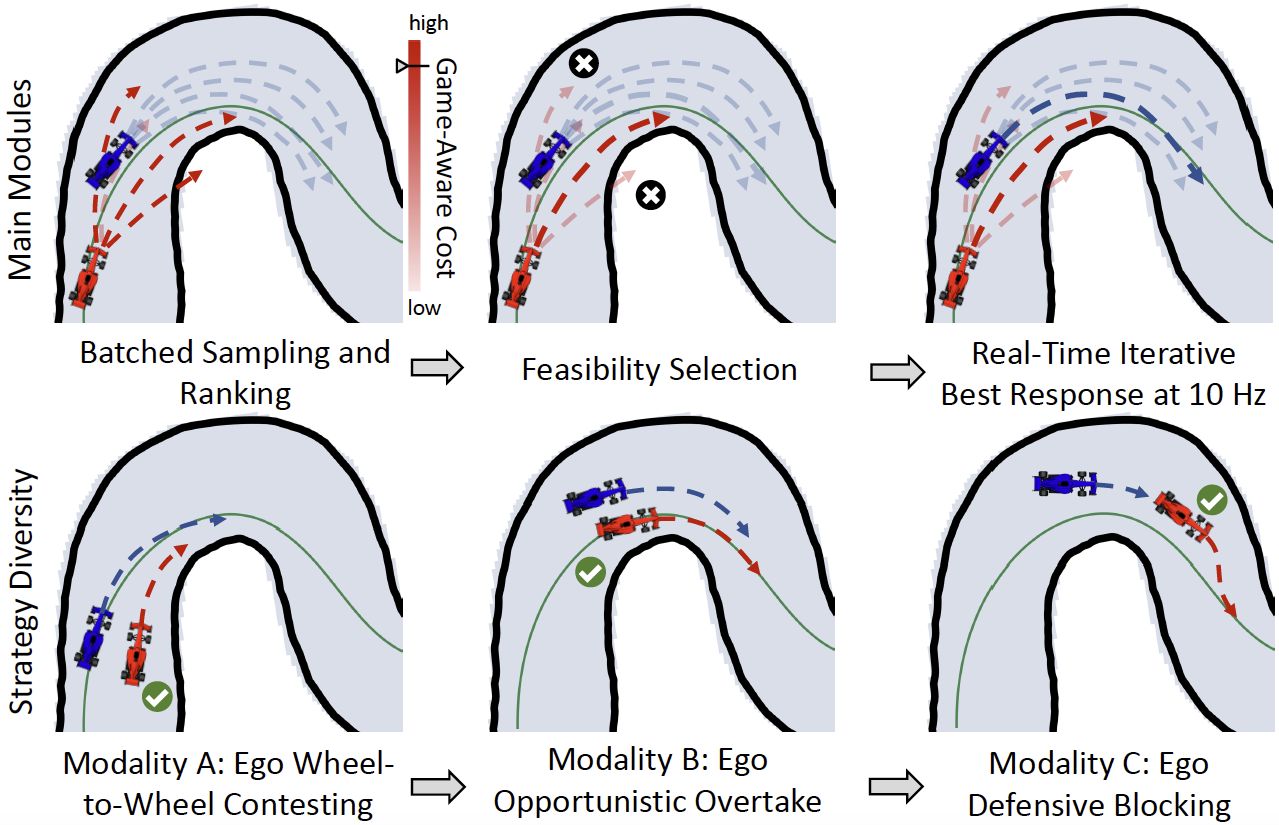
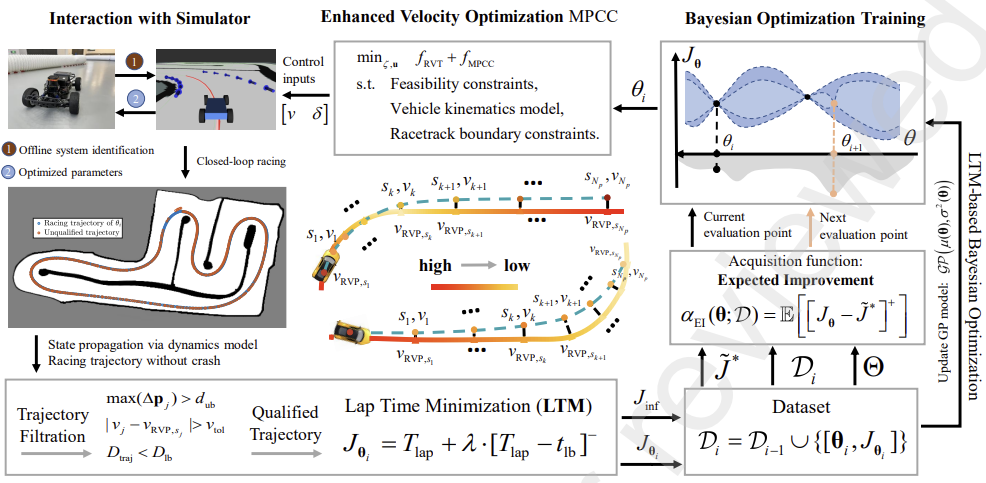
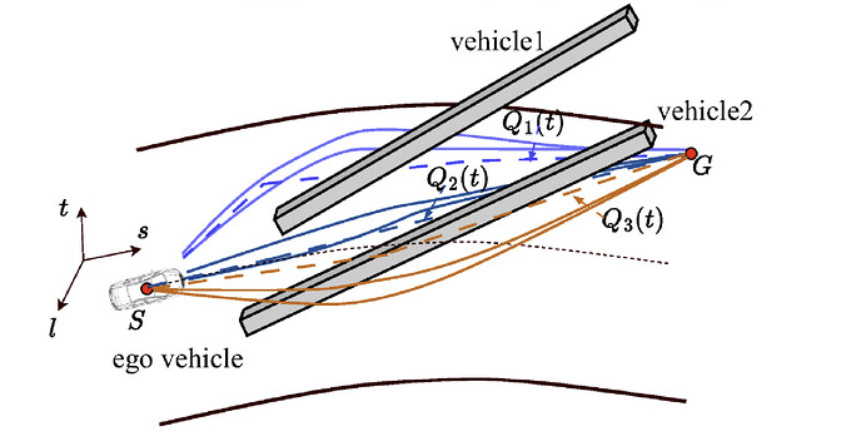
MPCC planning, overtaking, onboard learning, and scaled vehicle competition systems.
Selected Publications